0 likes
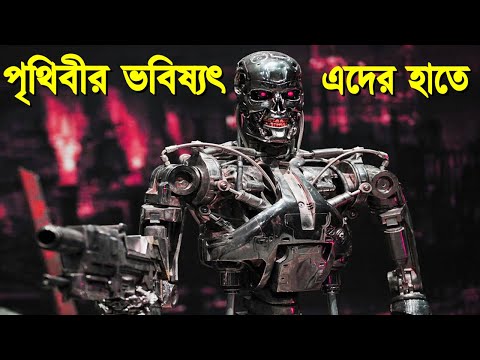
The MMCDS (Multi-Body – Multi-Contacts Dynamic simulator) simulator created at the Montpellier Laboratory of Informatics, Robotics, and Microelectronics …
The MMCDS (Multi-Body – Multi-Contacts Dynamic simulator) simulator created at the Montpellier Laboratory of Informatics, Robotics, and Microelectronics …