0 likes
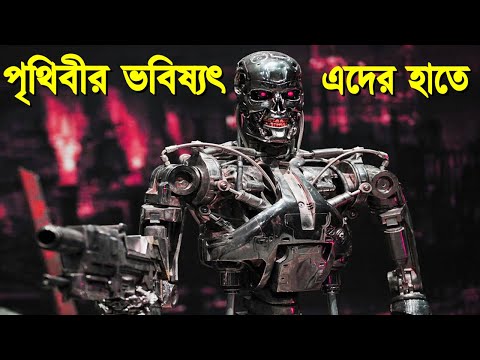
This is an illustration of the application of a hybrid kinematic/dynamic task-based control architecture for a squat on SHERPA (A biped robot designed by S. Krut).
This is an illustration of the application of a hybrid kinematic/dynamic task-based control architecture for a squat on SHERPA (A biped robot designed by S. Krut).